Simulation · Research infrastructure
Testing drones in simulation
At UAH, I built simulation environments and the tooling around them, from multi-aircraft missions to a Unity environment for human–AI research.
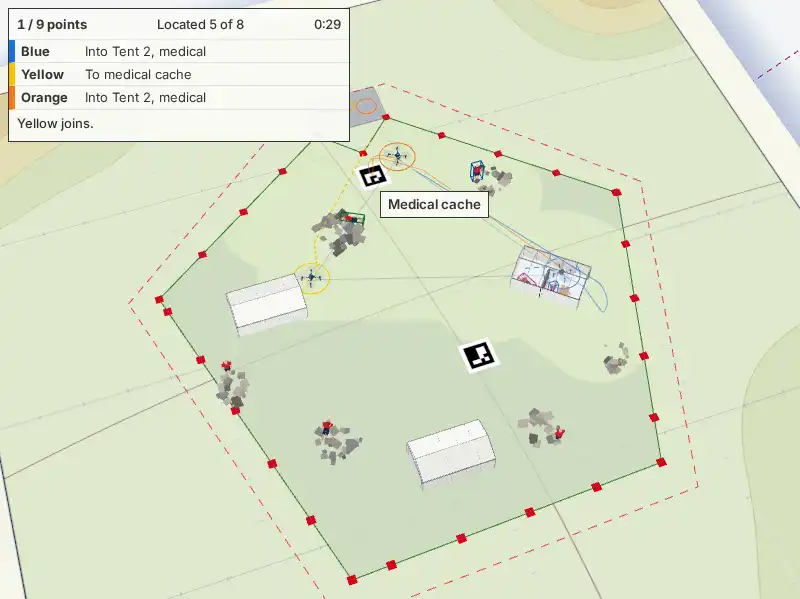
Simulating a mission
In Gazebo, we ran whole missions for SAPIENCE with PX4 software in the loop. That included custom airframes and cameras, as well as the mannequins and marked caches the aircraft had to find.
I built distributed simulation support, the CI/CD and container workflows used to run these tests, and the contract tests and fuzzers that exercised the running services. A grader scored each mission from its logs.
Running a simulated fleet
I ran 25+ drones in PX4 SITL on consumer desktop hardware using K3s. In the field, we deployed three real aircraft the same way, with a smaller set of services in the flight configuration.
Human–AI research in Unity
In a separate project, I built a Unity search-and-rescue environment with variable terrain, obstacles, and interactive mission conditions. It was used in more than 100 experiments.
You can find the related work in my publications.