Autonomous systems
UAH · NATO SPS
My work on SAPIENCE
I built the development and deployment workflow for our six-person student team, supported simulation at fleet scale, and helped fly our first flight on visual-inertial odometry.
AI engineer & pilot
I’m a senior AI engineer at Camgian and a commercial pilot.
With my team at UAH, I built a software factory that took code from push to real hardware, through multi-architecture images, physics simulation and a synced ground station. From that station, I helped fly our first autonomous flight on visual-inertial odometry.
At Radiance Technologies, I was a major contributor to modeling and simulation platforms. Then, as an ML research scientist, I built the MLOps infrastructure and GPU clusters behind my reinforcement-learning work.
I also built a Unity research environment, used in more than 100 experiments, that became the foundation of my master’s thesis.
Based in Huntsville, Alabama.
A few projects from UAH and Radiance Technologies, with notes on what I built and how it worked.
Autonomous systems
UAH · NATO SPS
I built the development and deployment workflow for our six-person student team, supported simulation at fleet scale, and helped fly our first flight on visual-inertial odometry.
Infrastructure
UAH · SAPIENCE
With my team, I built the tooling that stands up K3s, distributes images, and deploys services across the aircraft and ground station. We deployed three real aircraft with it, and scaled it to 25+ drones in simulation.
Flight
SAPIENCE · July 2026
In July 2026, during SAPIENCE development, we made our first autonomous flight with VIO as the estimator's only source of odometry. I worked on the robotics software and helped fly it from the ground station, deploying and monitoring the stack.
Simulation
UAH
I ran 25+ drones in PX4 SITL on consumer desktop hardware using K3s. I also built a Unity research environment used in more than 100 experiments.
Machine learning
Radiance · UAH
At Radiance Technologies, I built GPU training clusters and pipelines for reinforcement-learning control studies in AFSIM. Separately, at UAH, I contributed to training detectors and containerized them for deployment on embedded systems.
I studied aeronautics at the University of North Dakota, then computer science at UAH, and earned a graduate certificate in cybersecurity from Harvard Extension School. I’m also a commercial pilot with instrument and multi-engine ratings.
Experience, education, and publicationsAs an Autonomous Systems Engineer at UAH, I worked with a six-person student team on the NATO-funded SAPIENCE project. I built the development and deployment tools we used to test changes and get software onto the aircraft.
As a Machine Learning Research Scientist at Radiance Technologies, I worked on reinforcement learning in AFSIM and the infrastructure for training those models. That included GPU clusters and pipelines built with Ray, MLflow, Docker, and GitLab.
Earlier, as an intern at Collins Aerospace, I built flight-data-recorder tooling and certification test cases for Bombardier avionics, and at UND I built UAV swarm platforms flown in test flights. I’ve published three IEEE papers on human-AI teaming and UTM safety, and I’ve worked in Python, C++, PyTorch, ROS 2 and Kubernetes.
I publish research as Joseph Schwalb. My M.S. thesis at UAH studied explainable AI and human-AI teaming in virtual environments.
I’m working toward a Ph.D. in Computer Science at UAH, with graduation expected in Fall 2027.
Take an aircraft apart, replay a flight, follow one commit to a disconnected fleet, send a drone to a simulated survivor, or train 128 simulated vehicles. It all runs in your browser, with nothing to install.
Start with the aircraft
Loading the interactive route
This browser could not start the 3D view, so this is a still image of it.
Aircraft
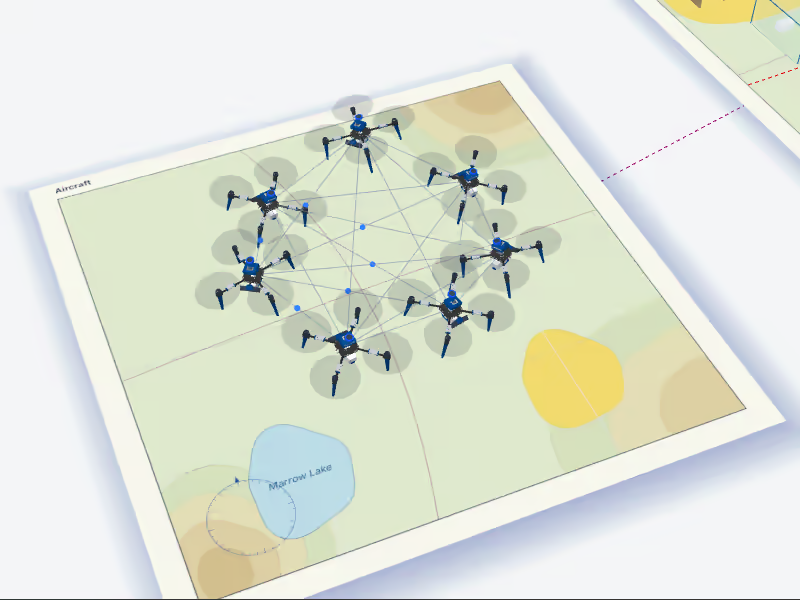
At UAH, our SAPIENCE team built search-and-rescue drones from off-the-shelf and printed parts. I worked on robotics software, machine learning pipelines and fleet deployment.
Interactive illustration. The fleet and radio traffic are simulated. Right-drag or use two fingers to orbit.
Infrastructure
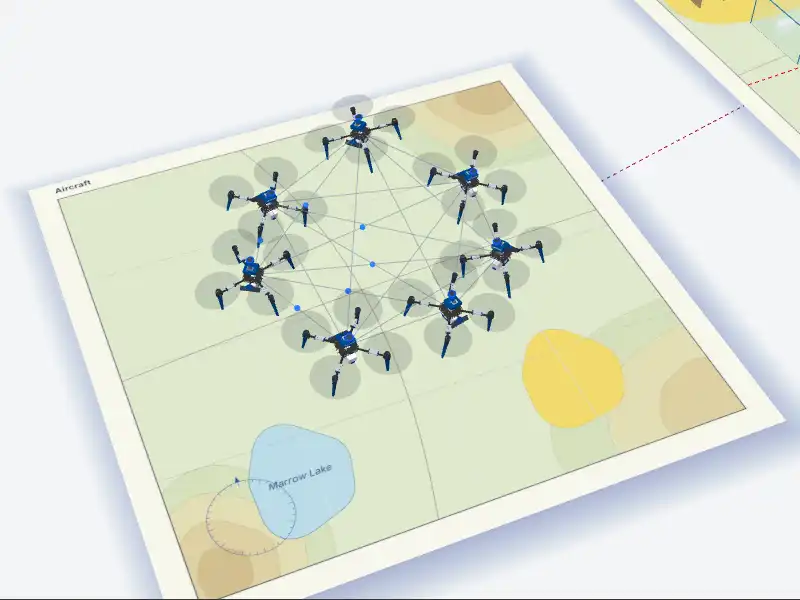
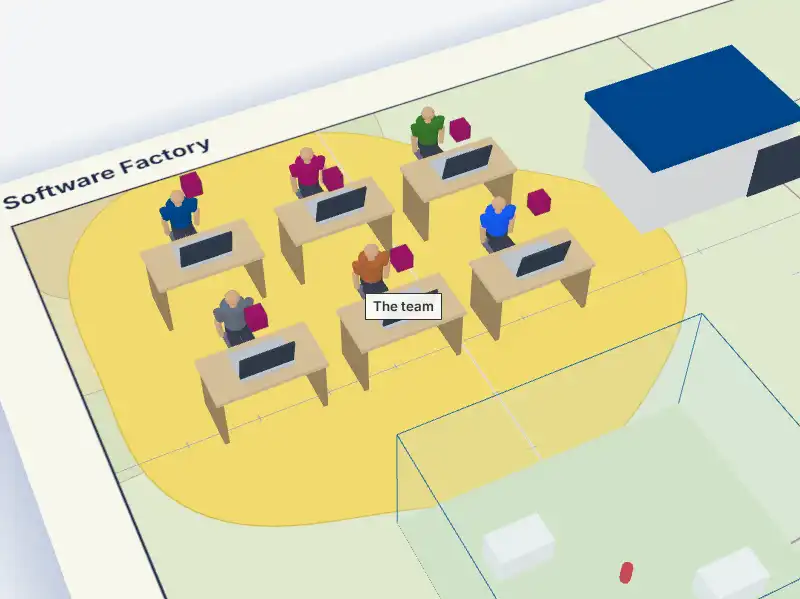
With my team, I built the SAPIENCE software factory: automated builds, simulation tests and airgapped deployment to our search-and-rescue (SAR) fleet.
Deployment case study · Simulation case study
Architecture illustration. A drawing of what we ran. A stripped-down stack was used for flight.
Mission
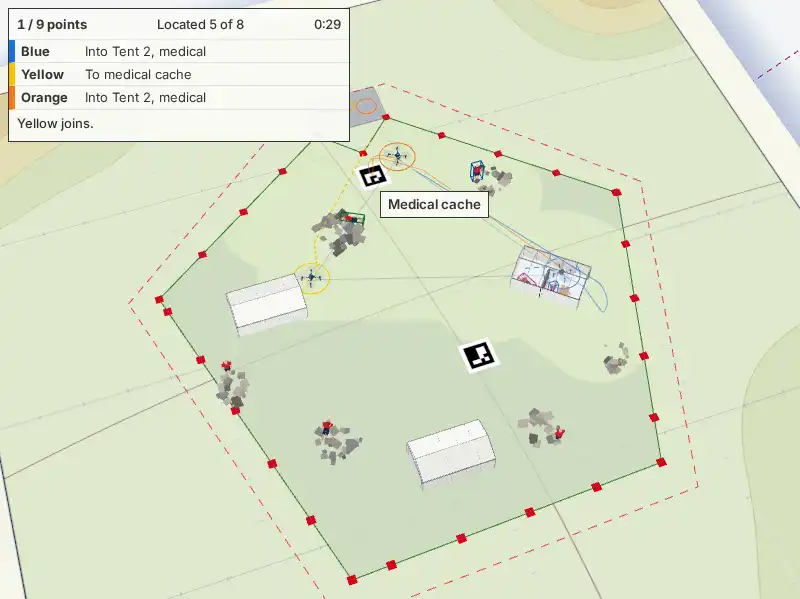
At the third NATO-funded SAPIENCE competition, our three aircraft had to fly a search-and-rescue scenario: locate eight survivors (mannequins) across a disaster zone and three collapsed buildings (tents) without GNSS, triage them, and land beside each one with the right package.
I built the deployment and simulation tests behind them, contributed to training the detectors, and containerized them for embedded deployment.
Mission illustration. Simulated in your browser from the competition’s rules, not a recording: no team served all eight in the real mission. Time is compressed and objects enlarged.
Flight
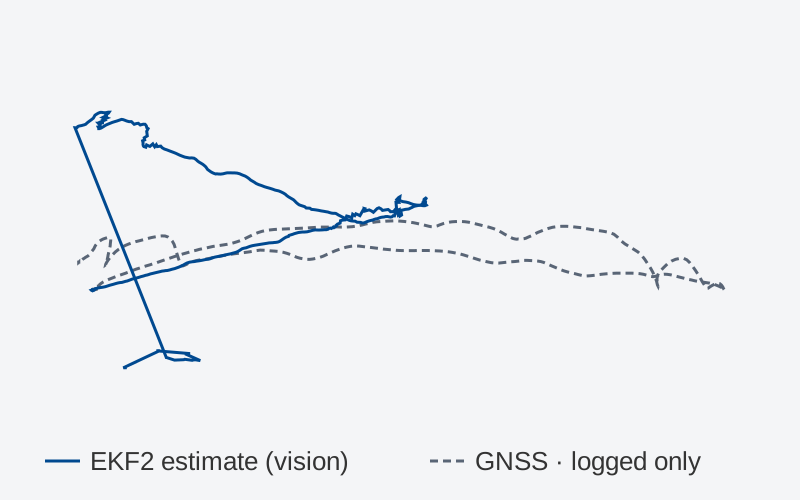
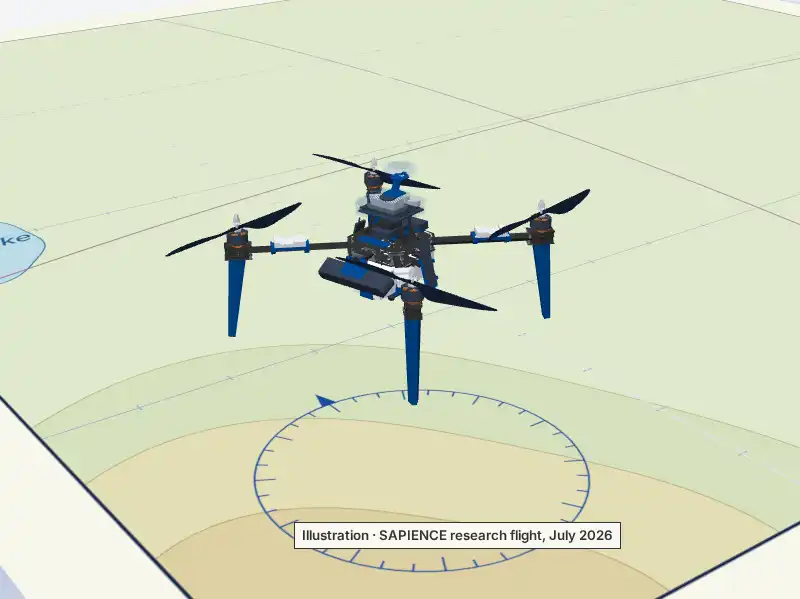
In July 2026, the stack from our software factory took off and flew our SAPIENCE aircraft with visual-inertial odometry (VIO) as its only odometry. I helped fly it from the ground station, deploying and monitoring the stack.
Getting the ZED SDK’s VIO working on our platform was non-trivial. Of all the SAPIENCE teams, our system flew the longest GNSS-denied, and it was the lightest, by almost half the weight.
These are real logs from our inagural VIO flight in July 2026!
Machine learning
At Radiance Technologies I developed online reinforcement-learning methods for AFSIM control studies, and built the GPU training clusters and pipelines behind them with Ray, MLflow, Docker and GitLab.
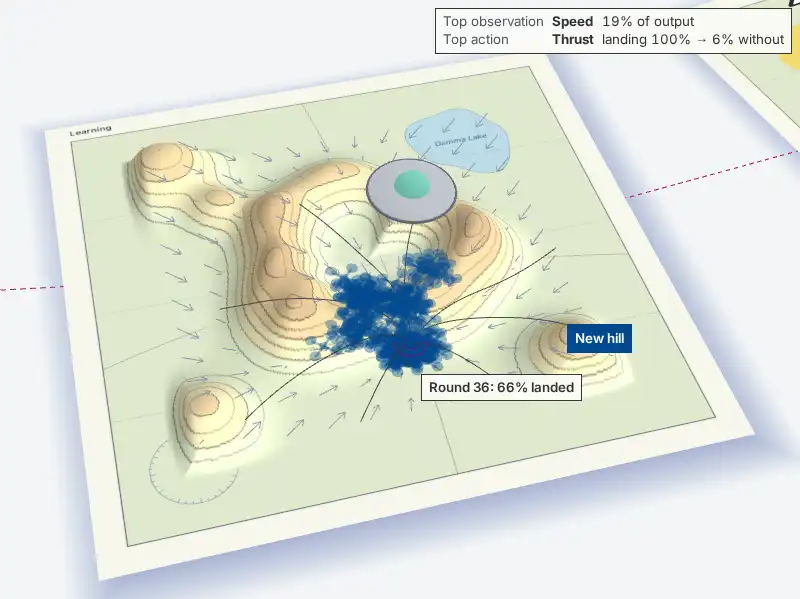
Browser demo. 128 simulated vehicles try to land inside a crater, learning live. Arrows show what the policy commands, and dark lines how it flies now. The alien ship is domain randomization: it keeps reshaping the field while they train.
Perception
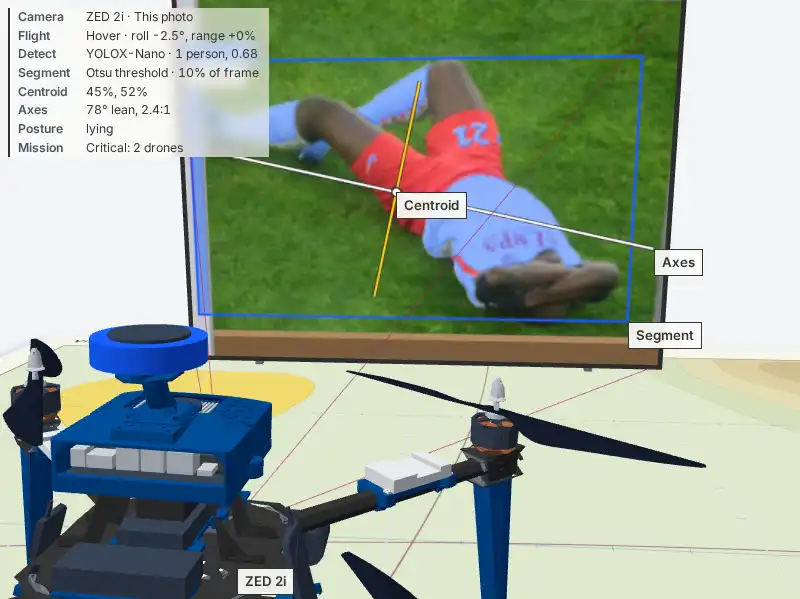
At UAH, I contributed to training the detectors, then containerized them for deployment on embedded systems.
Browser demo. Pretrained public models, running in your browser. The photo or live stream stands in for what the ZED 2i sees, and the hover, desk and wall are simulated.
If you’re hiring or have a question about my work, I’d be happy to hear from you. I can send a résumé.